English
 French
 German
Bearings for Humanoid Robot Joints and Actuators
WHERE THE TORQUE GOES
Humanoid robot bearings sit behind every question that reaches the bearing desk. Teams that spent years proving a machine can balance and walk are now building pilot lines, and each unit carries more joints. Every joint has to be light, quiet and repeatable.
A joint also has to hold torque in a small envelope, turn back and forth on command, and keep its accuracy through thousands of direction changes. This article walks the body joint by joint, then gives you a spec checklist and the path from sample to pilot run.
01Why a Humanoid Joint Is Hard on Bearings
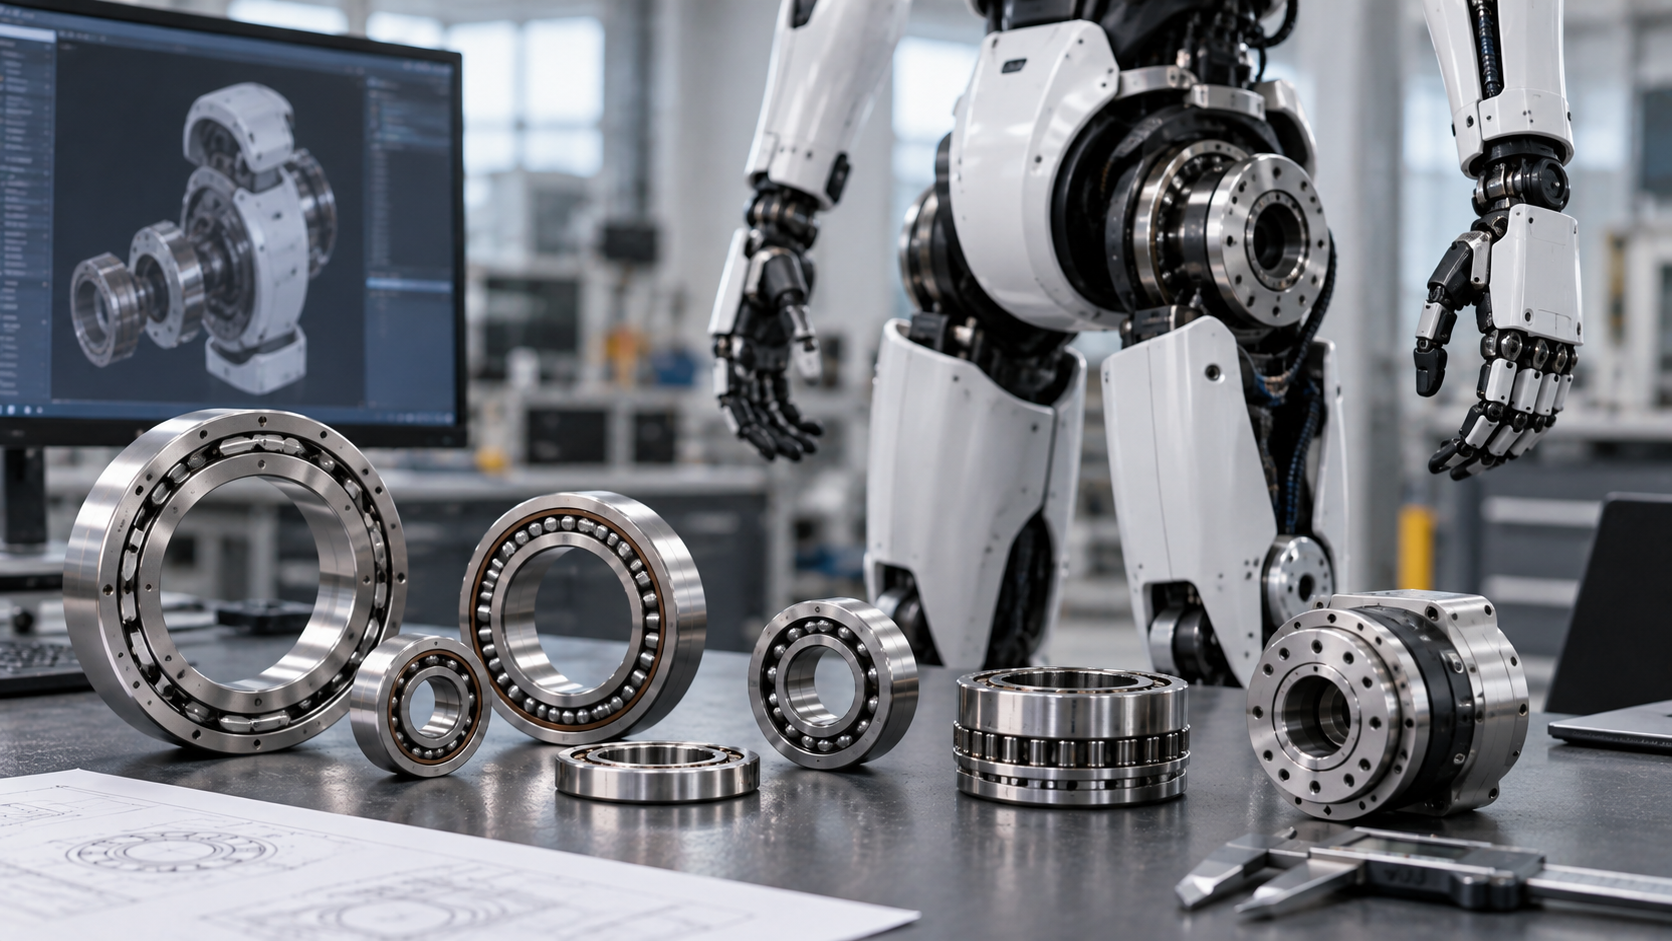
A humanoid joint packs a motor, a gearbox and a bearing into a package a person-sized machine has to wear. The bearing carries the weight on the shaft plus the moment created when the arm reaches out and the payload acts far from the joint center.
That distance is the moment arm, and it grows as the limb extends. With the arm straight out, the same payload becomes a far larger tipping load. A joint that feels smooth in a demo can turn noisy when the machine reaches far.
Back driveability adds a second requirement. Many joints must turn freely with the motor off, so a person can move the limb by hand. Friction in the bearing becomes resistance the control loop has to push through. The weight budget pushes the same way, since every gram in the joint is a gram the leg lifts.
Duty cycle is the last pressure point. A shift on a pilot line holds more direction changes than a lab test, and every reversal reloads the rolling elements. These machines work near people, so the joint has to stay quiet at low speed, where gear noise no longer hides a rough raceway.
02The Body Map, Joint by Joint
Walk the body from the shoulder down and the requirement changes at each stop. The pattern repeats in automation equipment with robot joints, where position holds under load all shift.
Shoulder and arm joints
The shoulder carries the whole arm as a cantilever, so the moment is high and the space is thin. Here the crossed roller bearing range earns its place, because one ring takes the moment and the radial load together. That removes a second bearing seat.
Wrist
The wrist stacks pitch and roll in a small package. Loads are lower than at the shoulder, so a thin section ball bearing often fits. Low friction and a flat profile matter most, because the control loop moves this joint more than any other.
Dexterous hand and fingers
Finger joints are small, lightly loaded and built in large numbers. Miniature deep groove ball bearings keep friction low and take the small radial loads a grasp creates. Consistency is the hard part, since dozens of these parts sit in one hand.
Hip and knee
These joints take the highest loads in the machine and see an impact each time a foot lands. The bearing has to carry radial load and a large moment together, then keep its tight fit after the shock. Crossed roller rings are common here.
Waist yaw
The waist rotates the whole upper body, so it carries weight plus the moment from any arm movement. One crossed roller bearing under the torso supports that load and sets the yaw angle at once. Splitting the job across two thin bearings costs height.
Linear actuators and screw support
Many leg designs push a ball screw instead of turning a joint directly. The screw needs support bearings at the fixed end, and those parts take the thrust plus side load from linkage misalignment. Mounting fits decide how much side load reaches the balls.
03Crossed Roller or Thin Section Ball Bearing
Both types appear in humanoid joints and neither wins everywhere. The table compares them on the points that decide a joint. The robotic actuator bearing page groups the options by joint function.
| Point of comparison | What it means inside a joint |
|---|---|
| Load direction | A crossed roller bearing takes radial, axial and moment load at once. A thin section ball bearing suits joints where radial load dominates. |
| Tilt stiffness | Crossed rollers sit at 90 degrees to each other, so the ring resists tilt with little deflection. A ball bearing tilts more. |
| Play after setting | Factory preload on a crossed roller ring removes internal play before it ships. A ball bearing needs a matched pair or a shim. |
| Friction and drag | Thin section ball bearings turn with lower friction, which suits a joint that back drives by hand. Crossed rollers add drag. |
| Size and unit cost | At small bores a thin section ball bearing is lighter and costs less. A crossed roller ring earns its cost at larger diameters. |
| Sealing and service | Either type runs sealed or open. A crossed roller ring is a closed unit for life, while ball bearings can be swapped. |
04What Belongs in the Joint Spec Sheet
A supplier can only answer well when the joint data is on the table. Send these items for every position and the reply becomes a bearing type, a size and a preload.
- Joint torque. Peak and continuous torque at the output, so the load path can be worked out.
- Moment arm. The distance from the joint center to where the load acts in the worst pose.
- Duty cycle. How often the joint reverses and how much of the shift it spends moving.
- Target backlash. The play allowed at the output, in arc minutes or at a stated radius.
- Radial and axial load. The force in each direction, including shock from a step or a stop.
- Mounting envelope. The bore, the outer diameter and the width the housing accepts.
- Weight limit. The mass budget for the bearing itself, since it sits far out on the limb.
- Seal or open. Whether the joint runs dry, greased for life, or sealed against dust.
- Target life. The hours or cycles the joint must reach before play grows past the limit.
05Preload and Backlash in a Joint
Backlash is the play you feel when you rock the output by hand with the motor off. In a robot joint it comes from three places, the gearbox, the coupling and the bearing. Teams blame the gearbox first, but a bearing in a loose fit adds its own share.
Preload removes that play by pressing the rolling elements into contact on both sides, leaving no free travel before the bearing takes load. On the RAU series the inner and outer rings are one integrated unit and the preload is set at the factory, so the builder does not shim parts on the line.
Measure at the output, not the bearing
Take the reading at the output with the joint assembled. The gearbox ratio multiplies whatever play the bearing adds, so a small movement at the input becomes a visible wobble at the hand. That output number is the one worth writing on the drawing.
Preload is a setting, not a maximum
Too little preload and the joint feels loose and the rollers skid instead of rolling. Too much and friction climbs, the motor works harder and back driveability drops. Our notes on crossed roller bearing failures match each damage pattern to the setting behind it.
06From Prototype to Pilot Run
A humanoid program rarely starts with a production order. It starts with one joint, one drawing and a question about whether the bearing can be made at all. The workable path is samples, then tooling, then batch.
Once the design stops moving, tooling locks in the raceway, the preload and the seal. That is where a custom size becomes a fixed part of the joint instead of a one-off sample. Our page on custom bearing manufacturing covers that step.
Yuanhe runs both product lines on one shop floor, with more than 500 B2B clients and more than 12,000 OEM projects behind the process. That matters at pilot stage, when the joint list shifts every few weeks.
07Frequently Asked Questions About Humanoid Robot Bearings
SEND THE JOINT LAYOUT
Send the joint list with the torque and the envelope for each position. We will come back with a bearing type, a size, a preload and a seal for every joint, and tell you which positions can start as samples.